
Epson IMU M-G330PDG UART/SPI


Free loan evaluation kits available!
Epson IMU M-G330PDG UART/SPI
The entry model of Epson's PDG series: a factory-calibrated 6-axis IMU for robots, AGVs and machines at a sensible cost.
Same 24 × 24 × 10 mm, 10 g footprint as the higher-performance PDG models, so your design can grow with your product.
Where the M-G330PDG fits best
Robots, AGVs and AMRs
Heading and tilt to support odometry and SLAM in service and logistics robots.
Agricultural and construction machines
Attitude for guidance, levelling and implement control.
Low-cost UAVs and UGVs
Stable attitude where the navigation filter gets frequent GNSS updates.
Motion tracking
Orientation and vibration capture in industrial equipment.
Allan deviation and key specifications
For systems that fuse the IMU with odometry, SLAM or GNSS, the M-G330PDG offers solid stability at the lowest cost in the series.
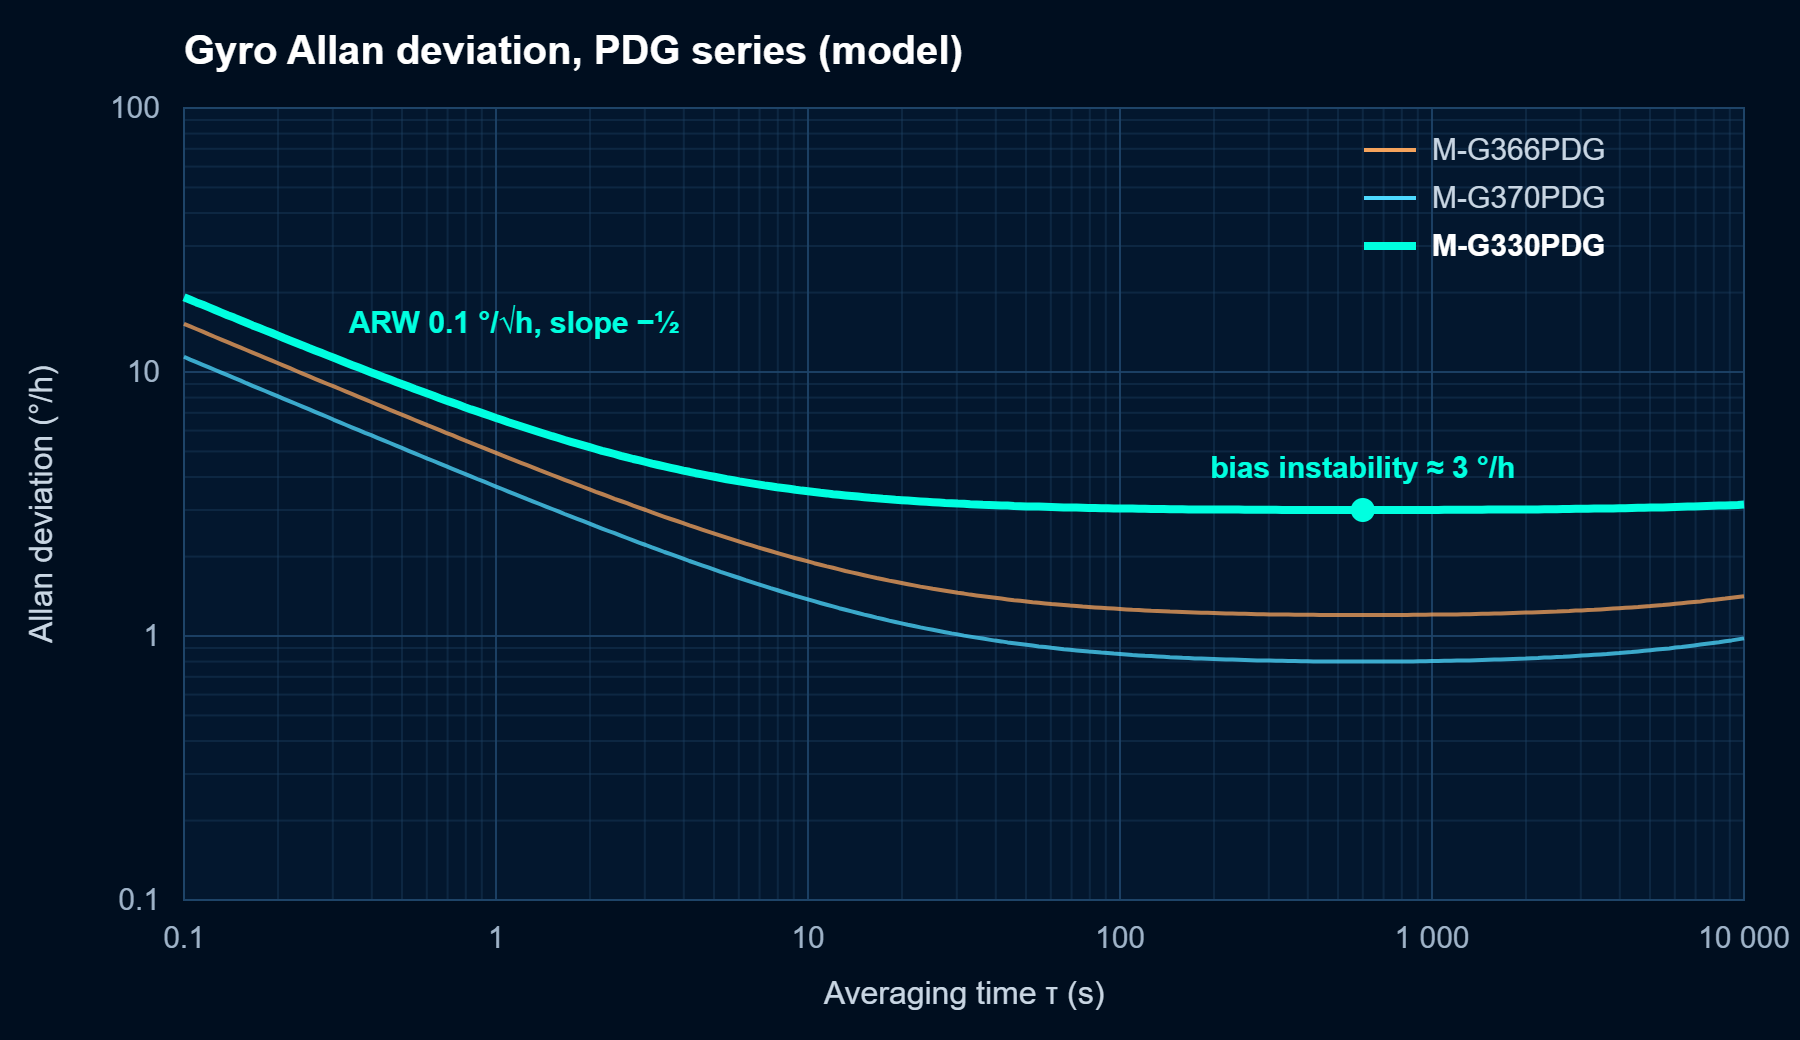
| Parameter | Typical value |
|---|---|
| Gyro bias instability | 3 °/h (average) |
| Angular random walk | 0.1 °/√h |
| Gyro range | ±400 °/s |
| Accelerometer range | ±8 g or ±16 g |
| Accelerometer bias instability | 34 µg |
| Velocity random walk | 0.03 (m/s)/√h |
| Output rate | up to 2000 Sps |
| Interface | UART or SPI |
| Supply | 3.3 V, 16 mA typ. |
| Operating temperature | −40 to +85 °C |
| Size, weight | 24 × 24 × 10 mm, 10 g |
Typical values from the Epson data sheet. The full data sheet is available on request.
One footprint, three performance levels
All three PDG models share the 24 × 24 × 10 mm footprint and connector. Move up or down in performance without a new board layout. Need longer heading hold? Step up on the same board.
M-G330PDG
Entry
Frequently asked questions
Is the M-G330PDG accurate enough for my robot?
For robots and machines that fuse the IMU with wheel odometry, SLAM or GNSS, 3 °/h bias instability is usually sufficient. If the IMU has to carry heading alone for longer periods, a higher PDG model is the better choice.
Can I upgrade later without a redesign?
Yes. The M-G330PDG, M-G366PDG and M-G370PDG share footprint and connector.
Which interfaces are supported?
UART or SPI; one of the two is connected.
Can I borrow an evaluation kit?
Yes, for qualified projects we lend an evaluation kit free of charge.
Compare it in your own system.For qualified projects we lend evaluation kits free of charge. Pricing and availability on request.
| Angular Random Walk (ARW): | 0.1 °/√h |
|---|---|
| Bias Instability (Accelerometer): | 34 μG |
| Bias Instability (Gyro): | 3 °/h |
| Country of Origin: | Japan |
| Dimension: | 24x24x10 mm3 |
| Interface (Protocol): | SPI , UART |
| Manufacturer: | Epson |
| Operating Temperature (max): | +85°C |
| Operating Temperature (min): | -40°C |
| Range (Accelerometer): | +/- 8G, +/- 16G |
| Range (Gyro): | +/-400 °/s |
| Series/ Type: | M-G330 |
| Supply Voltage, Vcc: | 3.3 V |
| Velocity Random Walk (VRW): | 0.030 (m/s)/√h |
More IMU's


