Skip to main content Skip to search Skip to main navigation

PRODUCTS

EPSON IMUs

Six-axis inertial measurement units with factory calibration, from compact 10 g modules to rugged IP67 units for vehicles and machines.
Request an evaluation kitCompare all Epson IMUs

0.03 °/√h

Angular random walk of the compact M-G370PDT (typ.)

0.5 °/h

Gyro bias instability of the M-G570PR (typ.)

IP67

Rugged M-G552 series and M-G570PR

Precise motion data from one compact module

An IMU combines three gyroscopes and three accelerometers and measures angular rate and acceleration on all axes. Navigation filters and controllers turn this into attitude, heading, velocity and position.

Epson IMUs are factory-calibrated over temperature and output digital data via UART/SPI, RS-422, CANopen or J1939. AMCORIS supplies the complete range and supports you from selection and evaluation to integration.

QUICK ANSWER

Which Epson IMU do I need?

Start with performance: gyro bias instability ranges from 3 °/h (M-G330PDG) down to 0.5 °/h (M-G570PR). Then choose interface and housing: compact UART/SPI modules for embedded boards, IP67 M-G552 units with CANopen, J1939 or RS-422 for vehicles and machines. For functional safety, the M-G355QDG complies with IEC 61508 SIL 1.

PERFORMANCE OVERVIEW

Gyro stability across the range

Gyro bias instability in °/h (typ.). Shorter is better.

M-G330PDG

3

M-G366PDG · M-G355QDG · M-G552Px1

1.2

M-G370PDG · M-G552Px7

0.8

M-G570PR

0.5

Sources: Epson data sheets M-G330PDG0, M-G366PDG0, M-G370PDG0, M-G552 series, M-G570PR20; Epson news release on the M-G355QDG0.
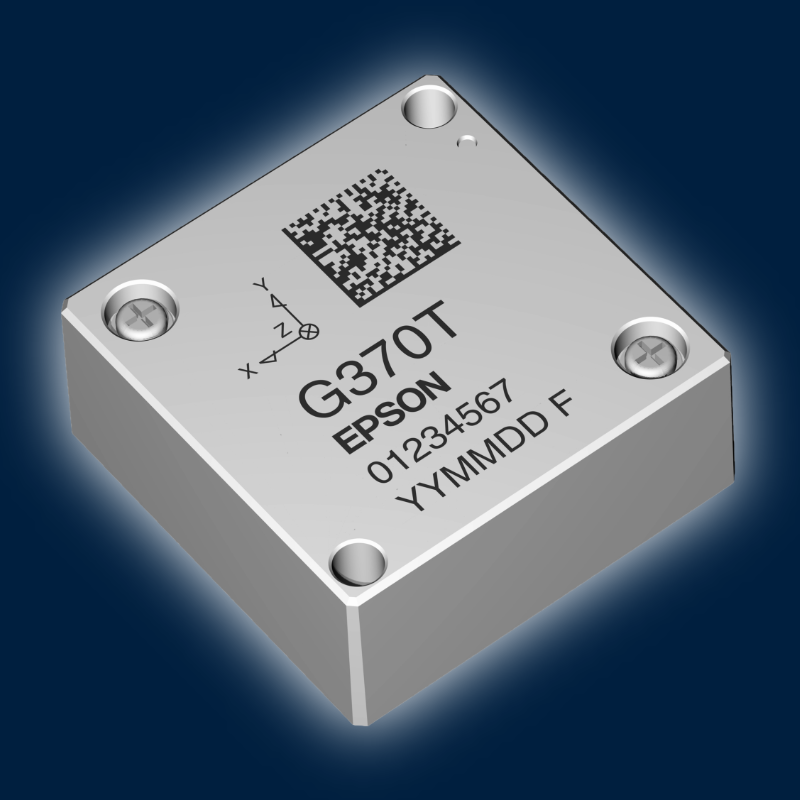
Epson M-G370PDT

SPOTLIGHT

M-G370PDT: the lowest-noise compact IMU

Same 24 × 24 × 10 mm footprint and 10 g as the PDG series, with halved angle noise. The first choice for camera gimbals, EO/IR payloads and compact INS boards where every hundredth of a degree counts.

Angular random walk

0.03 °/√h

Gyro bias instability

0.8 °/h

Output rate

up to 2 kSps

Temperature range

−40 to +85 °C

Interface

UART / SPI

Size and weight

24 × 24 × 10 mm, 10 g

Product details →

IMU PORTFOLIO

Find the right Epson IMU

All models measure six axes and are calibrated over temperature. Values are typical gyro bias instability and angular random walk.

Compact series

24 × 24 × 10 mm, around 10 g, UART/SPI. For drones, robots and embedded navigation.

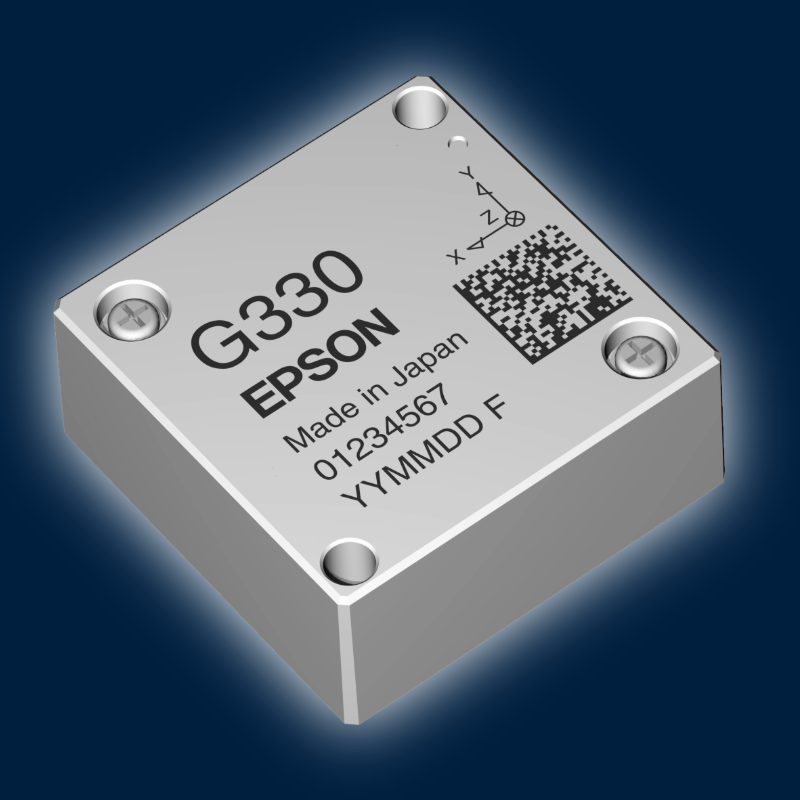
Epson M-G330PDG

M-G330PDGOn request

UART/SPI · 3 °/h · 0.1 °/√h

Cost-sensitive navigation and motion sensing.

Product details →

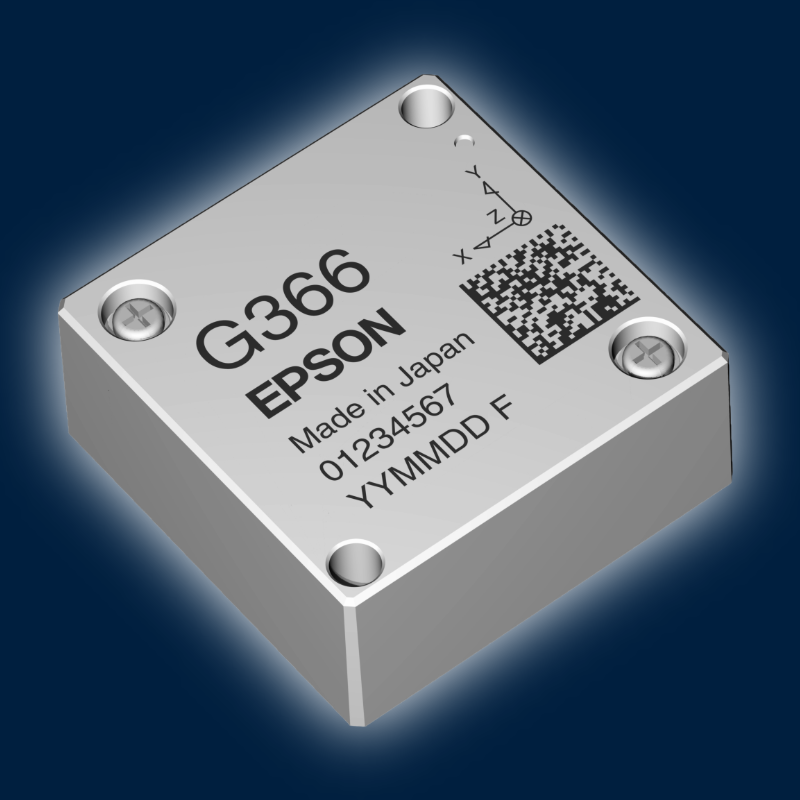
Epson M-G366PDG

M-G366PDGOn request

UART/SPI · 1.2 °/h · 0.08 °/√h

Small UAVs and robots with tight size and power budgets.

Product details →

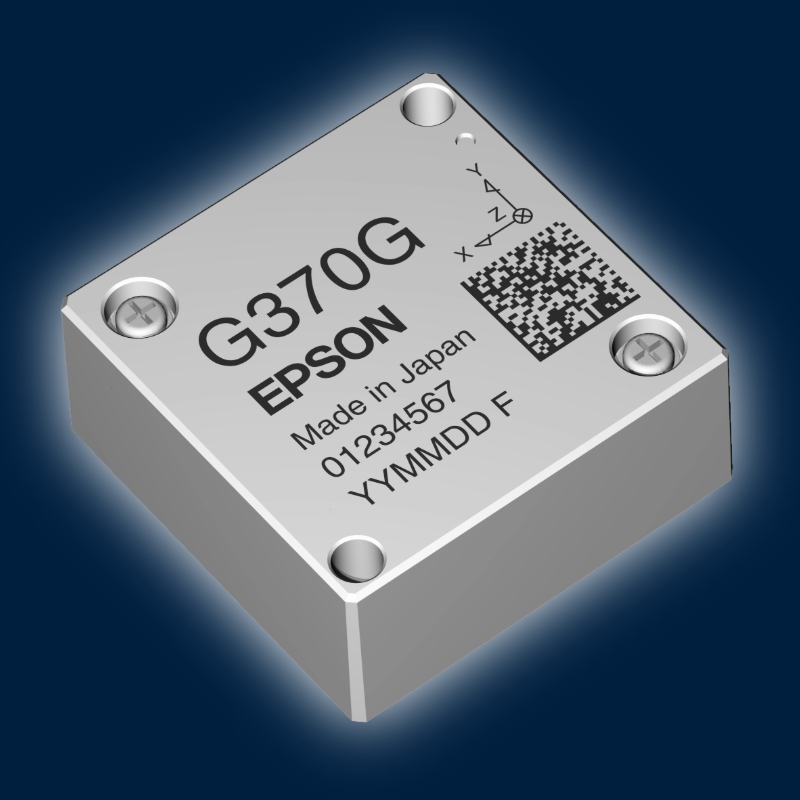
Epson M-G370PDG

M-G370PDGOn request

UART/SPI · 0.8 °/h · 0.06 °/√h

Precise heading and attitude in compact systems.

Product details →

LOWEST NOISE

Epson M-G370PDT

M-G370PDTOn request

UART/SPI · 0.8 °/h · 0.03 °/√h

Lowest angle noise in the compact package: gimbals, EO/IR and INS boards.

Product details →

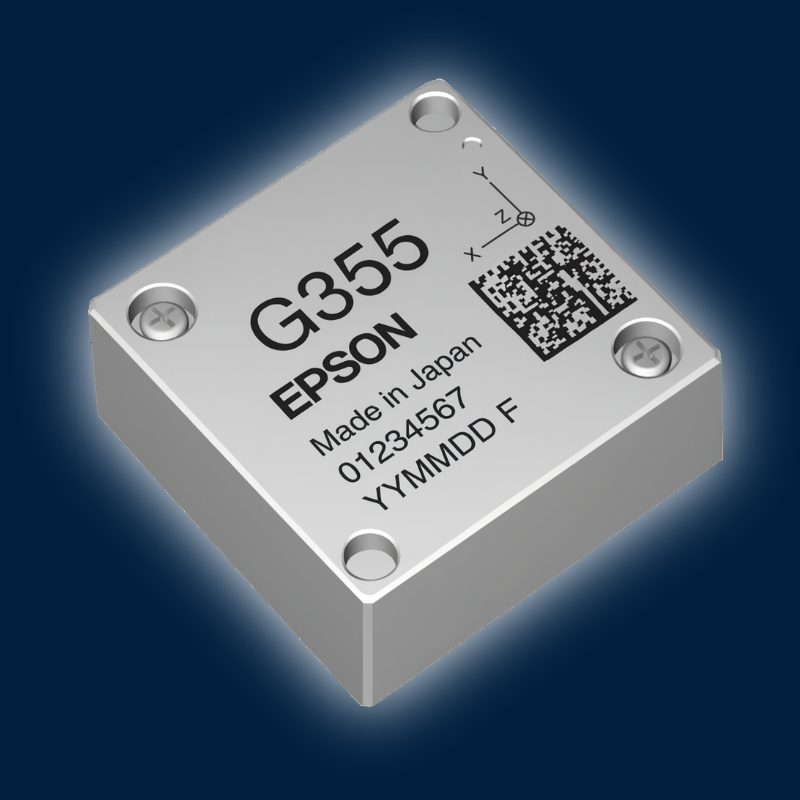
Epson M-G355QDG

M-G355QDGOn request

UART/SPI · IEC 61508 SIL 1 · 1.2 °/h

Safety-related functions in robotics and machinery.

Product details →

Rugged series

IP67 housing with vehicle and industrial interfaces. x1 variants 1.2 °/h, x7 variants 0.8 °/h.

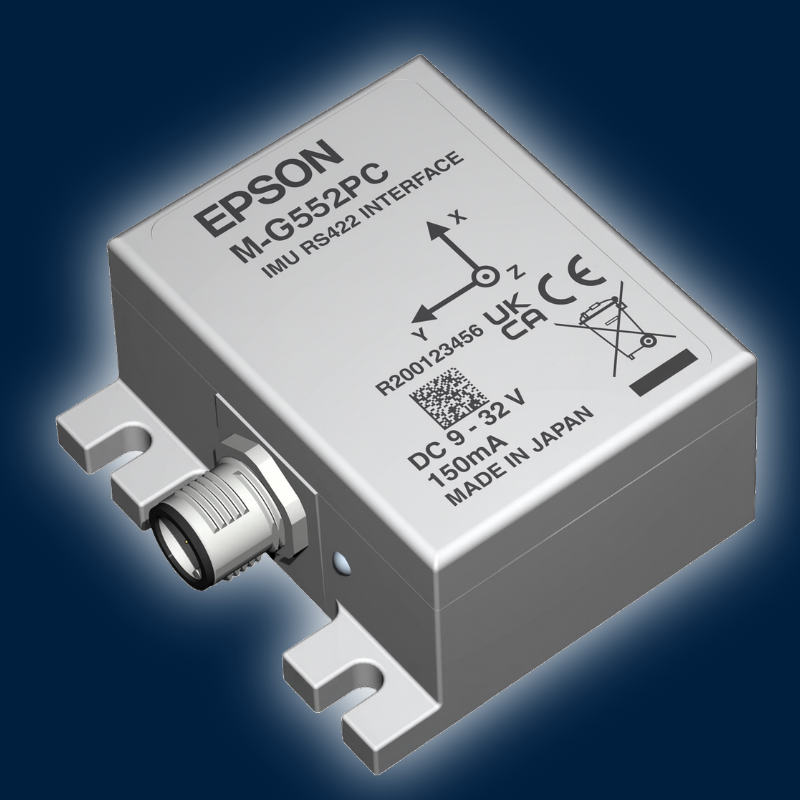
Epson M-G552PC1 / PC7

M-G552PC1 / PC7On request

CANopen · IP67 · PC1 / PC7

Vehicles, mining and mobile machines on a CAN bus.

Product details →

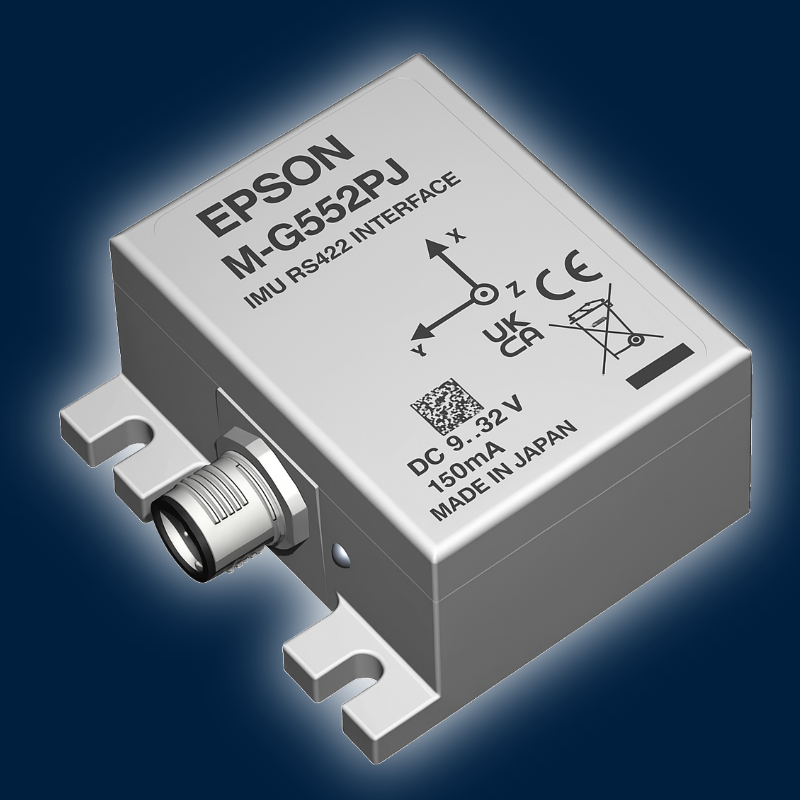
Epson M-G552PJ1 / PJ7

M-G552PJ1 / PJ7On request

SAE J1939 · IP67 · PJ1 / PJ7

Agricultural and construction machinery.

Product details →

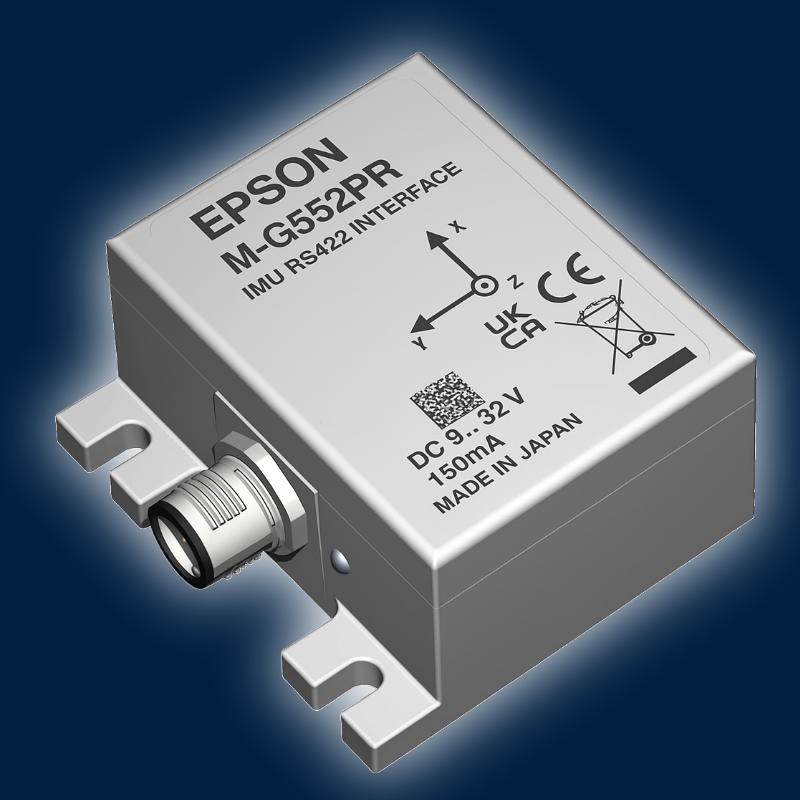
Epson M-G552PR1 / PR7

M-G552PR1 / PR7On request

RS-422 · IP67 · PR1 / PR7

Long cable runs and electrically noisy environments.

Product details →

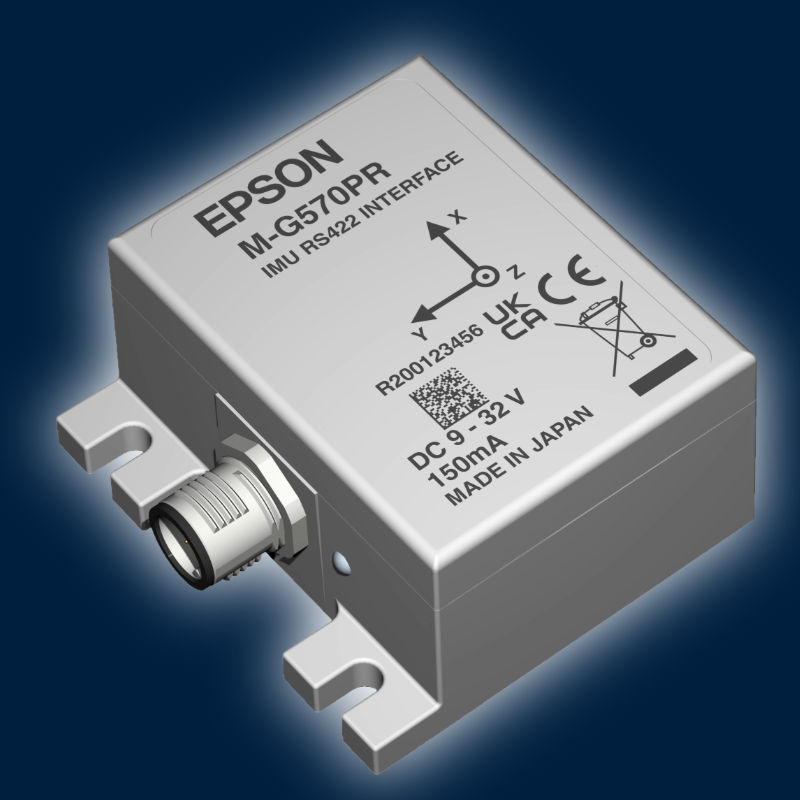
Epson M-G570PR

M-G570PROn request

RS-422 · 0.5 °/h · 0.04 °/√h · IP67

Highest accuracy for INS, survey and stabilization.

Product details →

IMUs in our applications

WHY AMCORIS

Why engineers choose AMCORIS

01

Complete Epson range

Compact, rugged and safety-certified IMUs from one source.

02

Every interface

UART/SPI, RS-422, CANopen and SAE J1939.

03

Application engineering

IMU selection, evaluation kits and integration support.

04

Factory calibrated

Temperature-compensated output, ready for your filter.

FAQ

Frequently asked questions

Your question is not listed?

Ask our engineers →

QWhat is the difference between an IMU and a gyro sensor?

A gyro sensor measures angular rate. An IMU combines three gyroscopes and three accelerometers in one calibrated module and provides everything needed for attitude and navigation.

QWhat do bias instability and angular random walk mean?

Bias instability describes slow drift of the gyro offset and limits how well heading is held over time. Angular random walk describes short-term noise and affects how smooth the angle estimate is.

QWhich interface should I choose?

UART/SPI for compact controllers and robots, RS-422 for long cables, CANopen or J1939 for vehicles and machines.

QCan I test the sensors before ordering?

Yes. Request an Epson evaluation kit from AMCORIS and test the sensor in your own setup. Our team helps you choose the right model.

Not sure which IMU fits?

Tell us about your application. We recommend a model and provide an evaluation kit for testing in your own system.

Request an evaluation kitCompare all Epson IMUs