
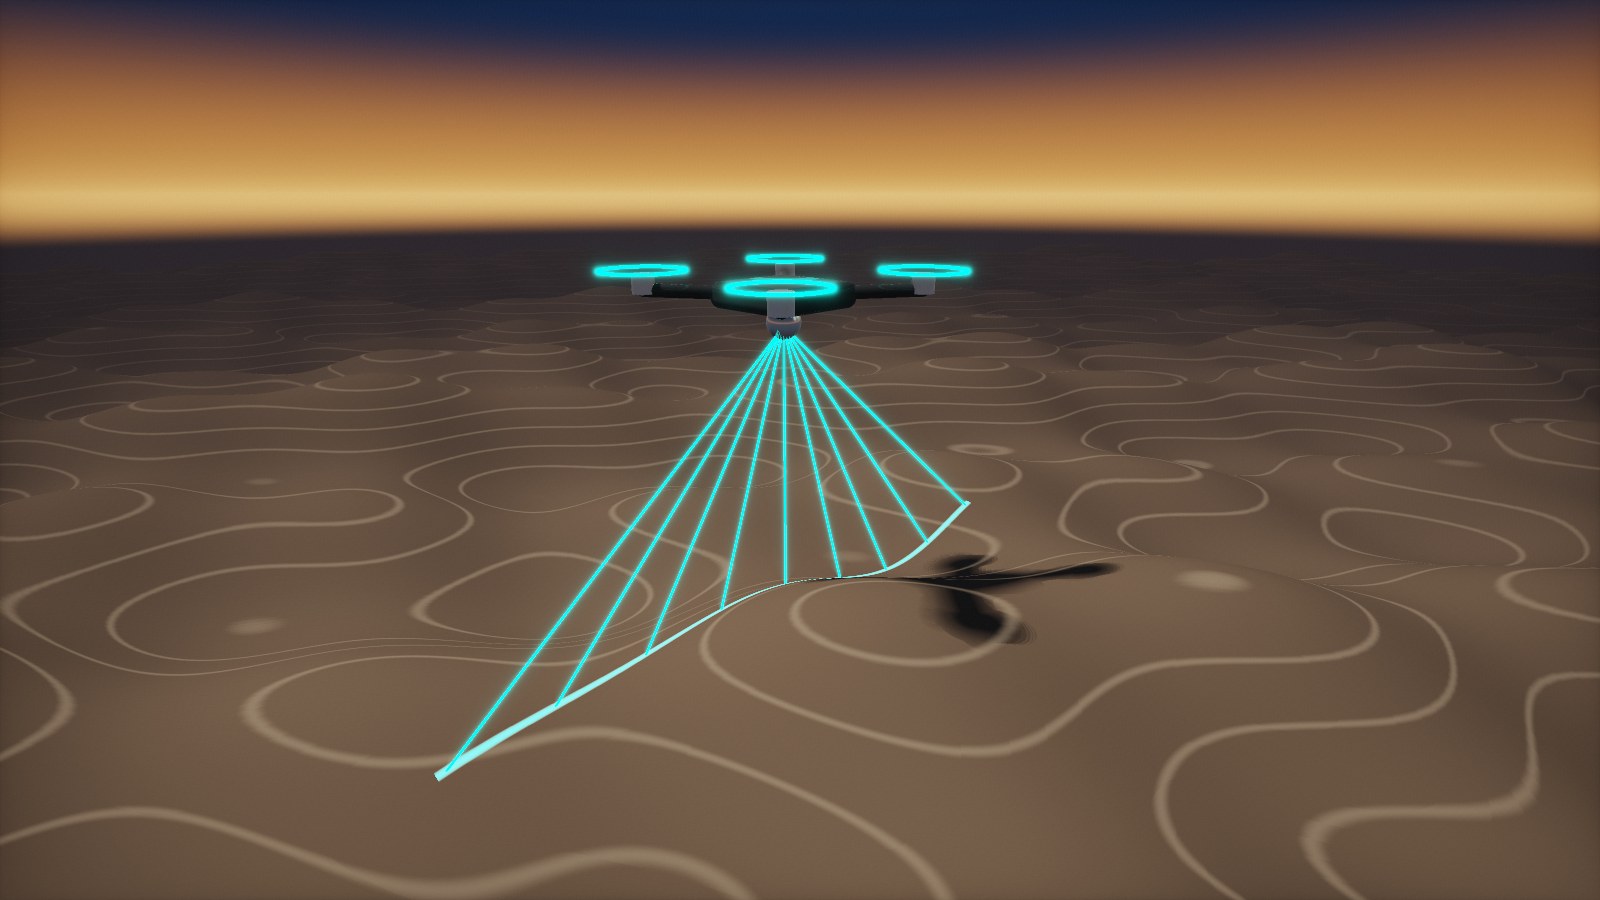
Every point needs position and orientation
A LiDAR or camera point is only as accurate as the position and attitude used to place it. GNSS provides the position; the IMU provides roll, pitch and heading at high rate and bridges short GNSS gaps under bridges, trees or buildings.
AMCORIS supplies Epson IMUs for mapping payloads and supports you from sensor selection and evaluation to integration with your GNSS receiver and scanner.
QUICK ANSWER
Which IMU specs matter for mapping?
Attitude accuracy drives point placement: at 100 m range, an attitude error of 0.01° moves a point by about 1.7 cm. Low gyro noise and bias instability are therefore key, together with clean time synchronisation to the scanner. The Epson M-G570PR reaches 0.04 °/√h and 0.5 °/h; the compact 10 g M-G370PDT reaches 0.03 °/√h and 0.8 °/h.


DIRECT GEOREFERENCING
How IMU data places every point
In direct georeferencing, every measurement is transformed into world coordinates using the position and attitude at the exact moment it was taken.
1
Timestamp
IMU, GNSS and scanner run on a common time base.
2
Orient
The IMU delivers roll, pitch and heading at high rate.
3
Fuse
A GNSS/INS filter combines position and attitude, often refined in post-processing.
4
Georeference
Each point is transformed into world coordinates.
Point offset at 100 m range caused by attitude error, in cm. Shorter is better.
0.1° attitude error
0.05° attitude error
0.01° attitude error
Sources: geometric calculation (offset = range × tan(error)); Epson data sheets M-G370PDG0 and M-G570PR20.

IMU SELECTION
Which Epson IMU for which mapping system
All IMUs combine three gyroscopes and three accelerometers with factory calibration over temperature. Values are typical gyro bias instability and angular random walk.
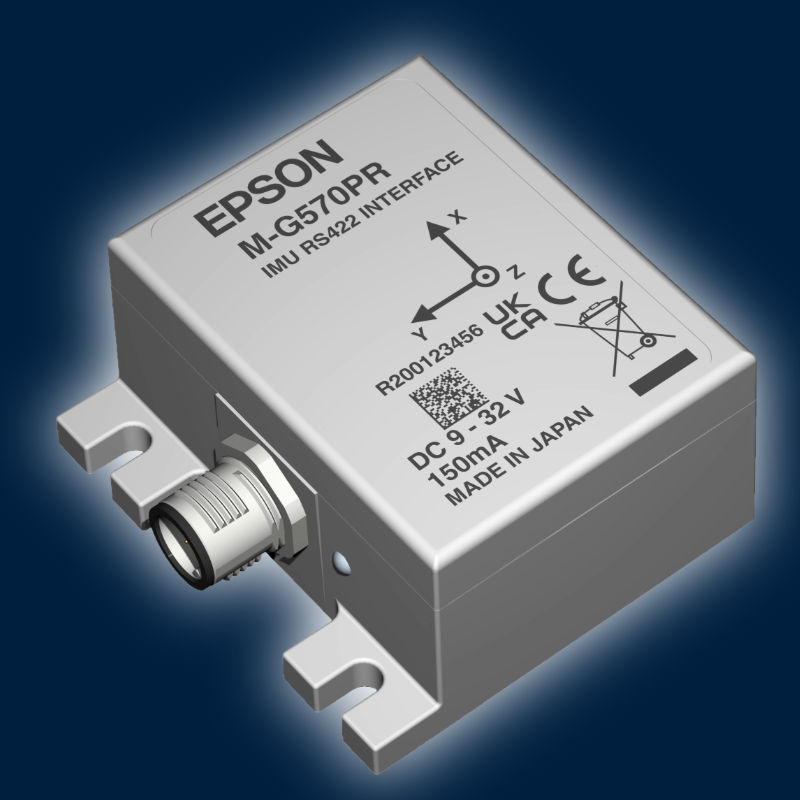
M-G570PROn request
RS-422 · 0.5 °/h · 0.04 °/√h · IP67
Survey-grade UAV, vehicle and vessel mapping.
Product details →RECOMMENDED
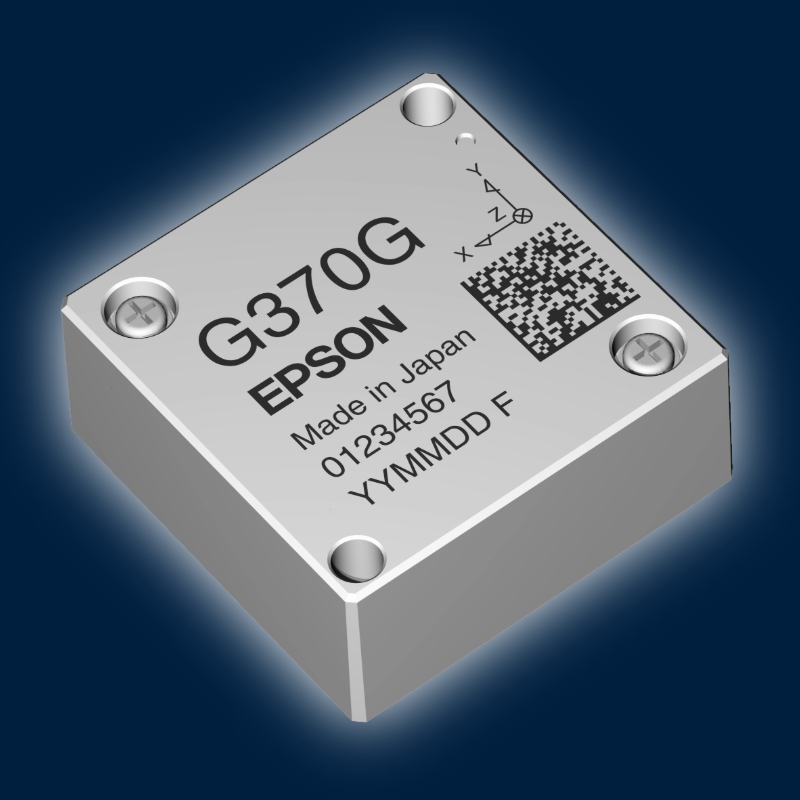
M-G370PDGOn request
UART/SPI · 0.8 °/h · 0.06 °/√h · 10 g
Lightweight UAV LiDAR and camera payloads.
Product details →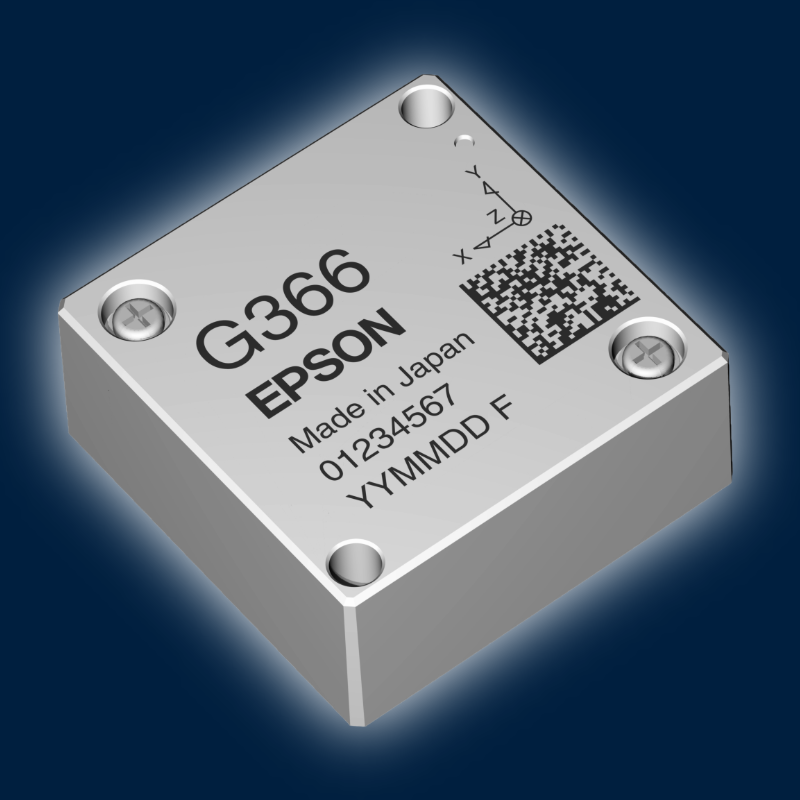
M-G366PDGOn request
UART/SPI · 1.2 °/h · 0.08 °/√h · 10 g
Handheld and backpack scanners, photogrammetry.
Product details →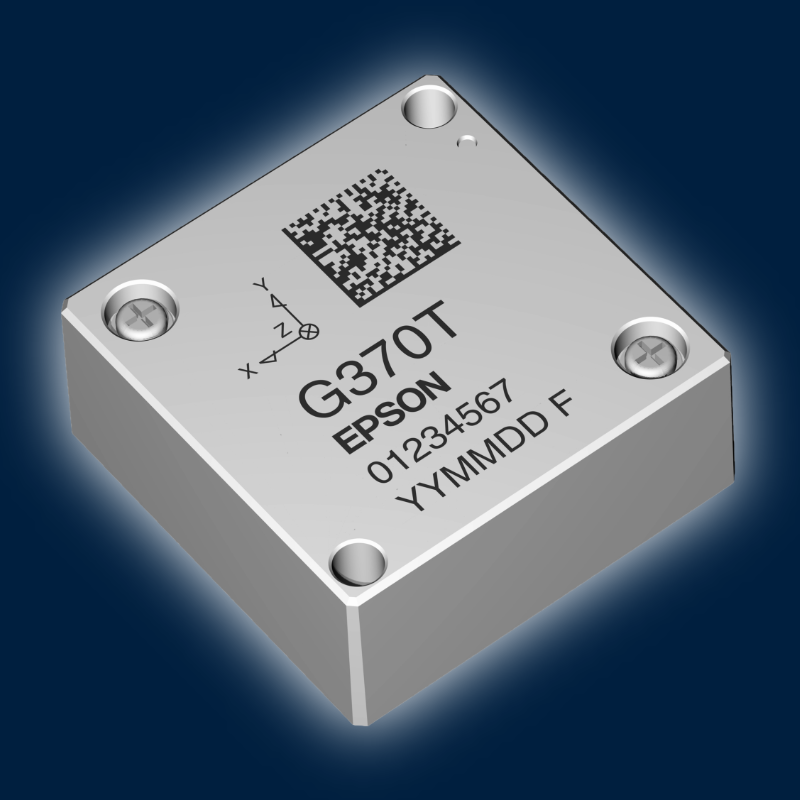
M-G370PDTOn request
UART/SPI · 0.8 °/h · 0.03 °/√h
Lightweight UAV LiDAR and camera payloads with the lowest angle noise.
Product details →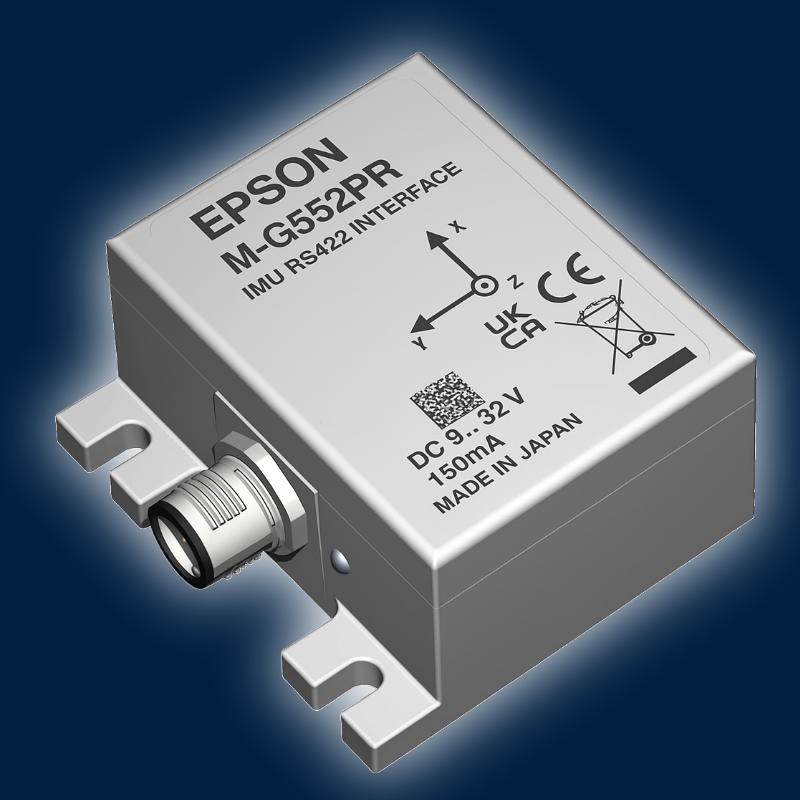
M-G552PR7On request
RS-422 · 0.8 °/h · 0.06 °/√h · IP67
Mobile mapping vehicles and vessels with long cables.
Product details →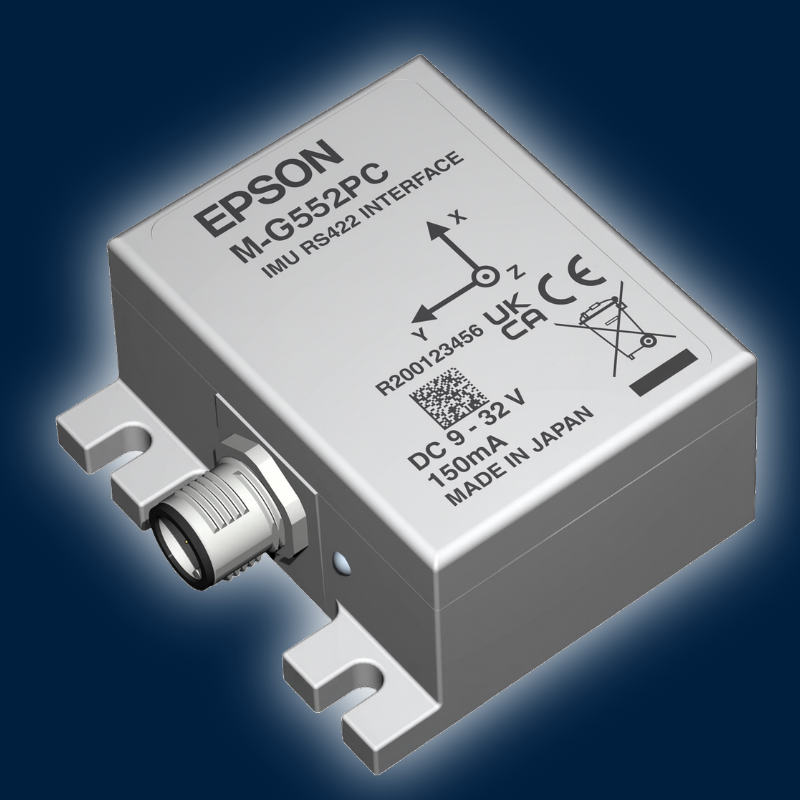
M-G552PC7On request
CANopen · 0.8 °/h · 0.06 °/√h · IP67
Mapping systems on vehicle CAN networks.
Product details →FROM AMCORIS PROJECTS
Integration example
A custom-tuned Epson M-G370PDG integrated into a survey drone kept the INS running through GNSS outages along power-line corridors and improved the georeferencing of the collected data.
-

Challenge
UAV Corridor Mapping
GNSS signal interruptions caused by dense canopy during high-precision corridor mapping along powerlines.
-
Solution
UAV Corridor Mapping
AMCORIS integrated a custom-tuned Epson M-G370PDG evaluation unit into the customer's navigation stack, providing high-accuracy inertial measurements for continuous positioning and sensor fusion.
-
Result
UAV Corridor Mapping
The result was uninterrupted INS operation during GNSS outages, improved SLAM performance, accurate geo-referencing and stable flight operation even under high wind conditions.
M-G370PDG
-

Challenge
Autonomous Mining AGV
Maintaining reliable vehicle navigation in underground tunnels where GNSS signals are unavailable.
-
Solution
Autonomous Mining AGV
Integration of the Epson M-G552PC with native CANopen support enabled direct communication with the vehicle's navigation controller without additional interface hardware.
-
Result
Autonomous Mining AGV
The result was seamless CANopen integration, reliable dead reckoning, reduced system complexity and continuous navigation in GNSS-denied underground environments.
M-G552PC7

WHY AMCORIS
Why engineers choose AMCORIS
01
Mapping expertise
Experience with UAV, vehicle and handheld mapping systems.
02
Low-noise attitude
ARW down to 0.03 °/√h (M-G370PDT) and bias instability down to 0.5 °/h.
03
Application engineering
IMU selection, evaluation kits and integration support.
04
Built for the field
IP67 variants for vehicles, vessels and outdoor use.
QWhat is direct georeferencing?
Each LiDAR or image measurement is placed in world coordinates using the GNSS position and the IMU attitude at that moment, without or with fewer ground control points.
QHow does attitude error affect point accuracy?
The offset grows with range: at 100 m, 0.01° of attitude error moves a point by about 1.7 cm, 0.1° by about 17.5 cm.
QCan the IMU bridge GNSS outages?
Yes, for short outages under bridges, trees or buildings. The IMU carries the attitude and position until GNSS returns; the achievable time depends on the IMU and the motion.
QCan I test the IMUs before ordering?
Yes. Request an Epson evaluation kit from AMCORIS and test the IMU in your own setup. Our team helps you choose the right model.
More IMU's


EVALUATION KIT
Test it in your own system
Epson evaluation kits are available from AMCORIS as a free loan for qualified projects. Share a few details about your application and we prepare the right kit and support you during the evaluation.
✓Free loan for qualified projects
✓Help with model selection and set-up
✓Direct line to our application engineers


